AGV Controller Design: Splitting Navigation, Avoidance and Scheduling
Not every job belongs on the main SoC. Hard-realtime control on an MCU with perception and scheduling on the host is the sturdier design.
Task split matters more than TOPS
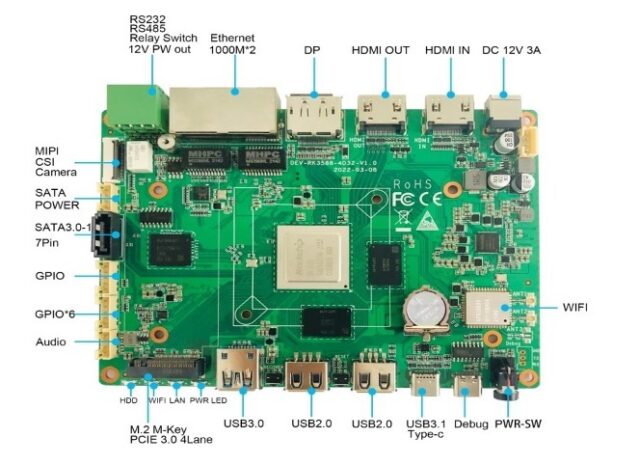
- Layered architecture: motor loops and safety stop on an MCU; SLAM and visual avoidance on the RK3588 host;
- Compute allocation: lidar SLAM is CPU-bound, visual avoidance is NPU-bound — budget 8 cores and pin CPU affinity when running both;
- Comms: use CAN or a fixed-length serial protocol between host and MCU, not TCP — radio noise on the floor makes IP unreliable.
The most overlooked AGV requirement is emergency-stop latency — the safety loop must cut motor enable directly, bypassing the host.
Related products: IPA-RK3588 industrial board, RP01A dev board. Datasheets, firmware and SDKs are free at the Hugsun Documentation Center; for selection advice or volume pricing, talk to us.